Task 01
Conveyor Cup
A single arm retrieves cups from a conveyor moving at 16 m/min within a short interception window.
Anonymous review materials
One-Step Generation with Explicit Execution-Time Allocation
Overview
SECD repeatedly retrieves cups from a conveyor moving at 16 m/min using one network evaluation per action chunk.
Paper
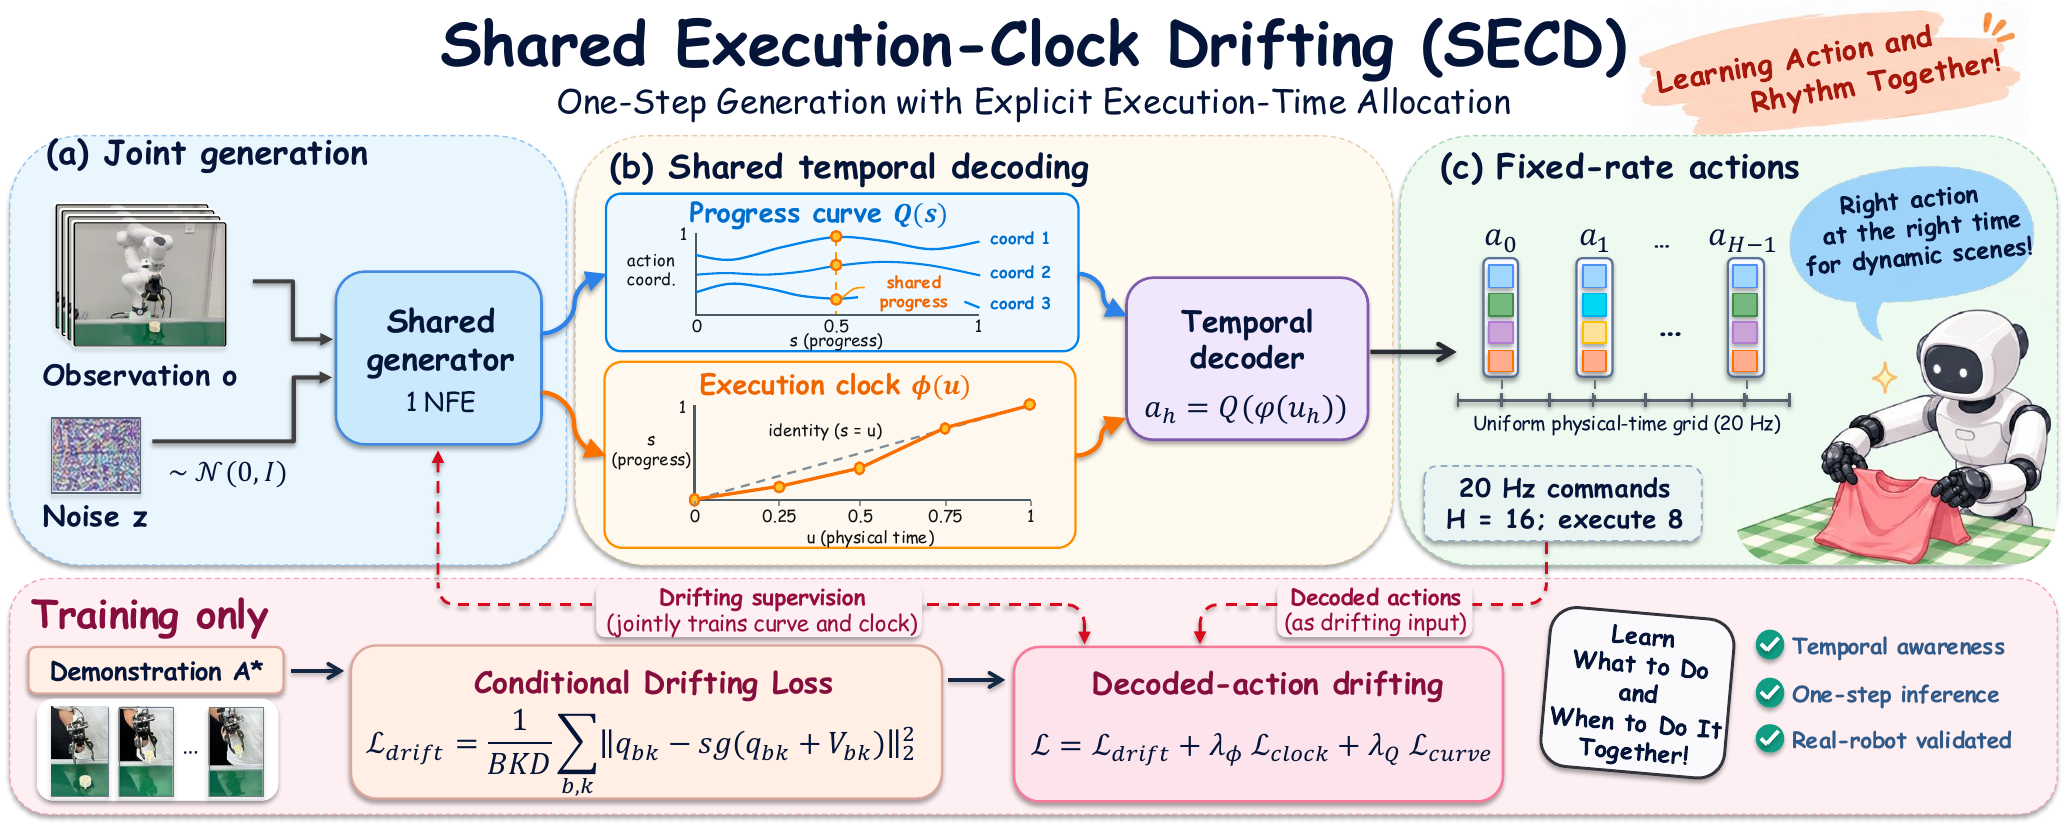
Manipulation under time constraints requires both accurate actions and an execution rhythm that matches the evolving scene. This becomes critical when a robot must intercept moving objects or complete a sequence of adjustments before a deadline. Although one-step policies reduce generation cost, their directly predicted action sequences leave temporal allocation implicit. We propose Shared Execution-Clock Drifting (SECD), which makes execution rhythm an explicit part of one-step action generation. Conditioned on an observation and a latent sample, the policy jointly predicts a progress-indexed action curve and a shared monotone clock that maps fixed control times to locations on the curve. Demonstration-derived alignment anchors this decomposition, which is trained jointly through drifting on the decoded actions. The resulting policy retains a fixed-rate control interface and requires one network evaluation. We evaluate SECD across four real-robot tasks with inference on NVIDIA Thor. Across 300 trials, it achieves 77.00% task-averaged success and outperforms the evaluated one-step baselines on every task, including 91% success in cup retrieval from a 16 m/min conveyor and 54% in restoring and folding a crumpled shirt within 90 s. A fixed-clock variant reaches 79% on the same conveyor protocol. Complementary state-based RoboMimic experiments, including cross-seed ablations on Transport and Square, further support the joint design of the temporal representation and demonstration alignment.
Method
The method jointly models an action progress curve and an execution clock, then decodes fixed-rate actions on a uniform physical-time grid.
Real-world evaluation
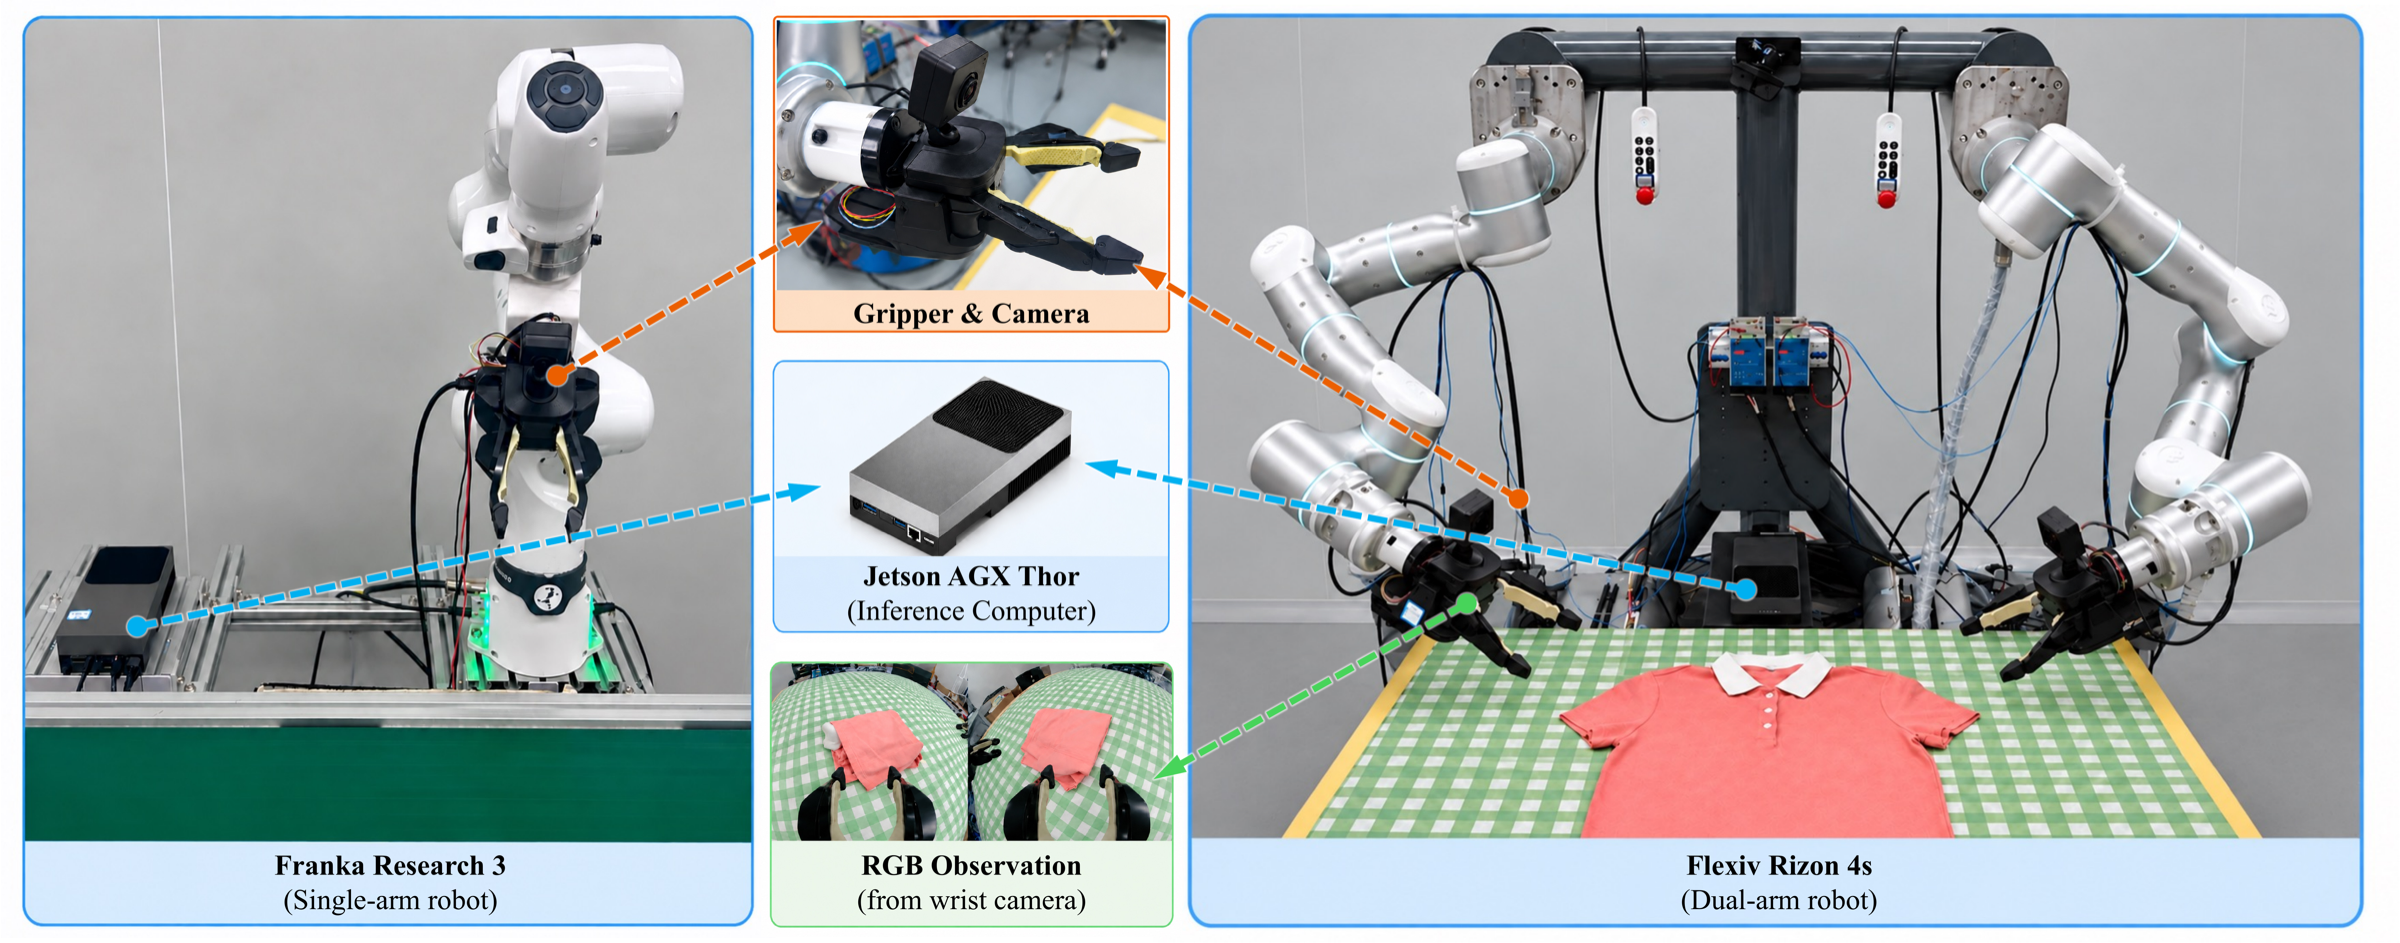
Experiments use single-arm and dual-arm robot platforms with wrist-camera observations and onboard inference.
Robot experiments
Representative rollouts compare DP (16 NFE), OneDP, Naive Drifting, and SECD under shared task data and robot-side deployment settings.
A single arm retrieves cups from a conveyor moving at 16 m/min within a short interception window.
The robot must restore a randomly crumpled shirt and complete the full folding sequence within 90 seconds.
Two arms fold both sleeves of a flat shirt, complete two half-folds, and reorient the shirt between folds.
A dual-arm system grasps a stationary cup and places it on a randomly positioned coaster.
Evaluation
Real-robot success rate and mean policy inference time on NVIDIA Thor across 300 trials.
| Method | NFE | Latency (ms) | Cup Place | Fold (Flat) | Fold (Crumpled) | Conveyor Cup | Average |
|---|---|---|---|---|---|---|---|
| DP | 16 | 252 | 98.0 | 74.0 | 30.0 | 0.0 | 50.50 |
| OneDP | 1 | 26 | 71.0 | 38.0 | 22.0 | 31.0 | 40.50 |
| Naive Drifting | 1 | 24 | 83.0 | 48.0 | 26.0 | 56.0 | 53.25 |
| SECD (Ours) | 1 | 25 | 95.0 | 68.0 | 54.0 | 91.0 | 77.00 |
Success rate (%). Each policy is evaluated on 100 Cup Place, 50 Fold (Flat), 50 Fold (Crumpled), and 100 Conveyor Cup trials. Bold denotes the highest success in each task.
Analysis
A separately trained variant replaces the learned execution clock with a uniform fixed clock while retaining the curve head.
Both evaluations use 100 cups on the same 16 m/min conveyor protocol. The 12-point difference supports the complete aligned temporal representation.